I am a PhD student jointly affiliated with Fudan University and the Shanghai Innovation Institute, working at OpenDriveLab under the supervision of Prof. Hongyang Li.
My research interests center on Humanoid Loco-Manipulation and Human Data Scaling. Always happy to chat and exchange ideas — feel free to drop me an email.
🔥 News
- 2026.09: 📢 EgoHumanoid-V2 is on arXiv!
- 2026.05: 🎉 EgoHumanoid is accepted by RSS 2026 and fully open-sourced!
- 2026.02: 🎉 Joined Tongyi Lab, Alibaba as a Research Intern.
- 2026.02: 📢 Released EgoHumanoid on arXiv — a human-to-humanoid loco-manipulation transfer framework.
- 2026.01: 🎉 WholeBodyVLA is accepted by ICLR 2026!
📝 Selected Publications
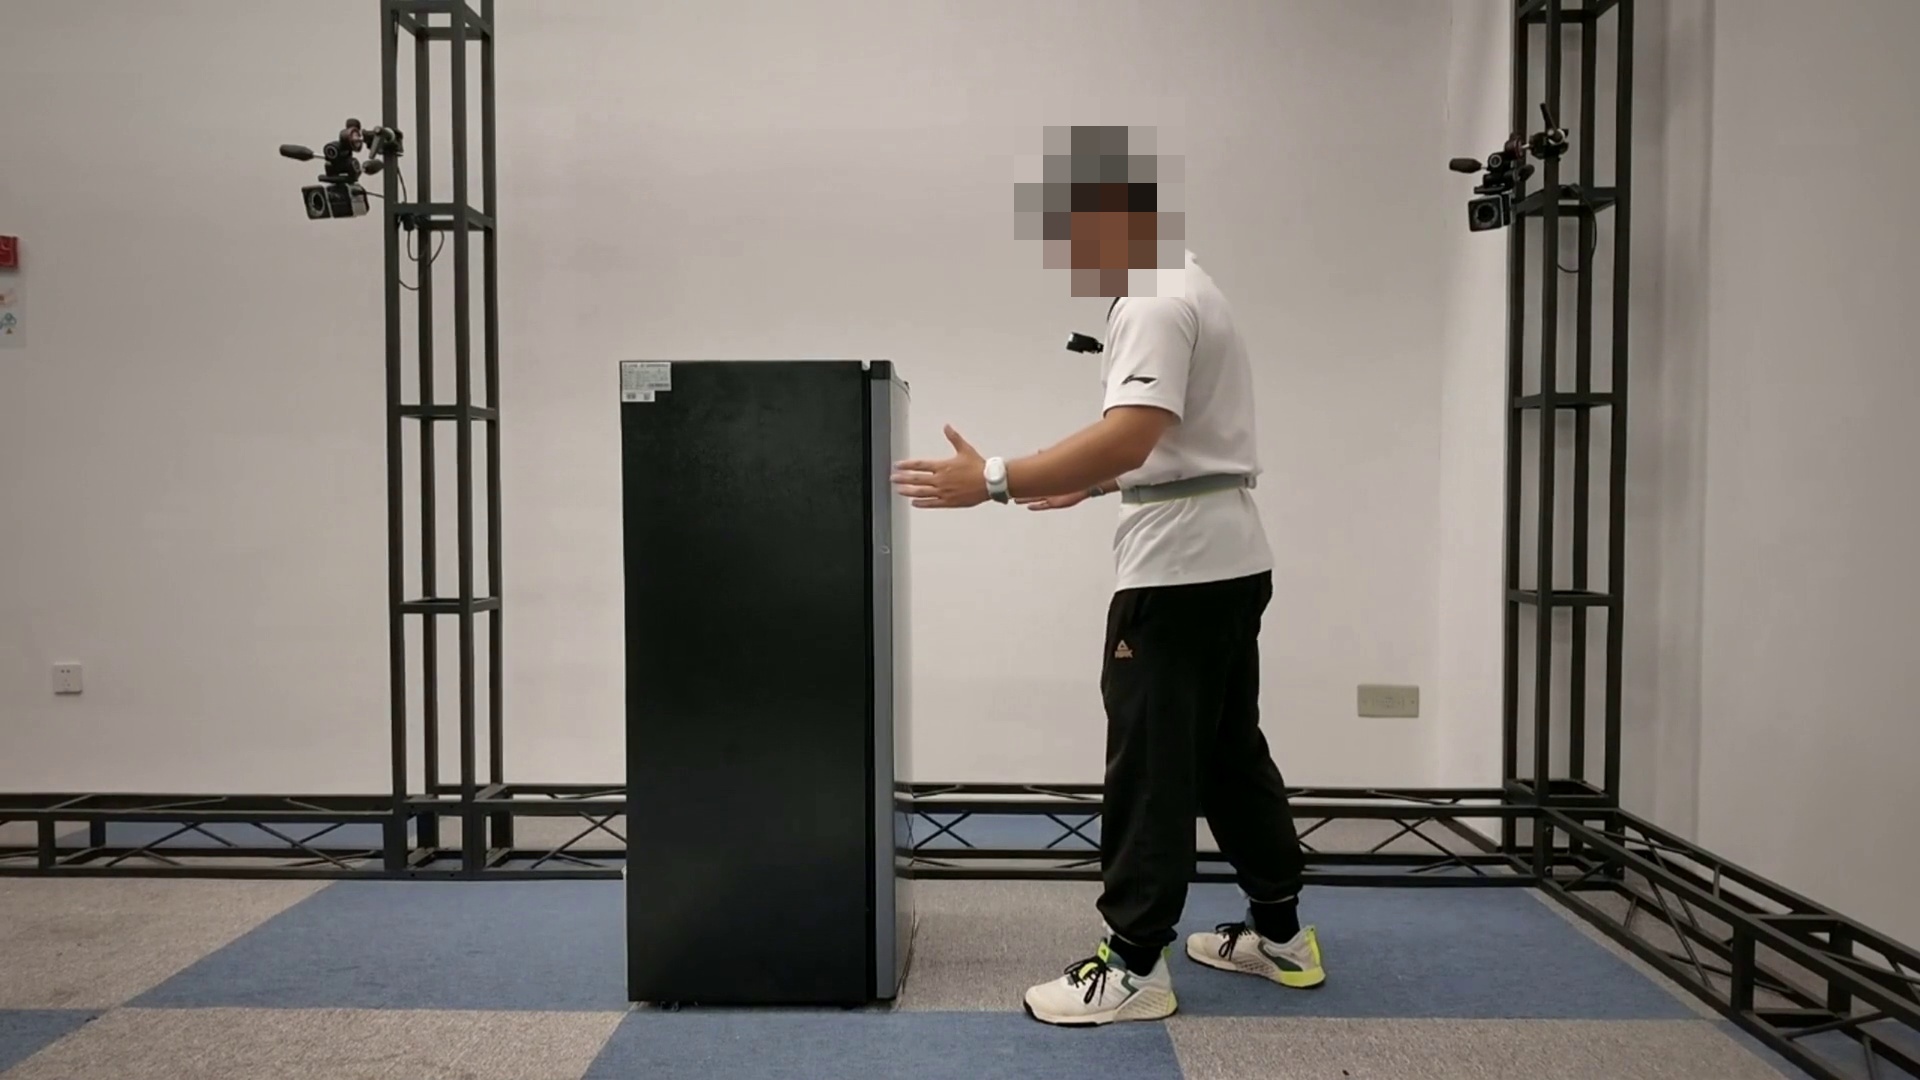
EgoHumanoid-V2: Human-to-Humanoid Transfer of Coordinated Whole-Body Skills for Loco-Manipulation
Jin Chen, Yiming Jiang, Chongyang Xu, Modi Shi, Shijia Peng, Li Chen, Tianyu Li, Mu Xu, Yilun Chen, Steven Hoi, Hongyang Li
arXiv preprint, 2026
Transfers coordinated whole-body skills from egocentric human demonstrations through coarse-to-fine action alignment and visual alignment, with zero-shot deployment on four real-world tasks.
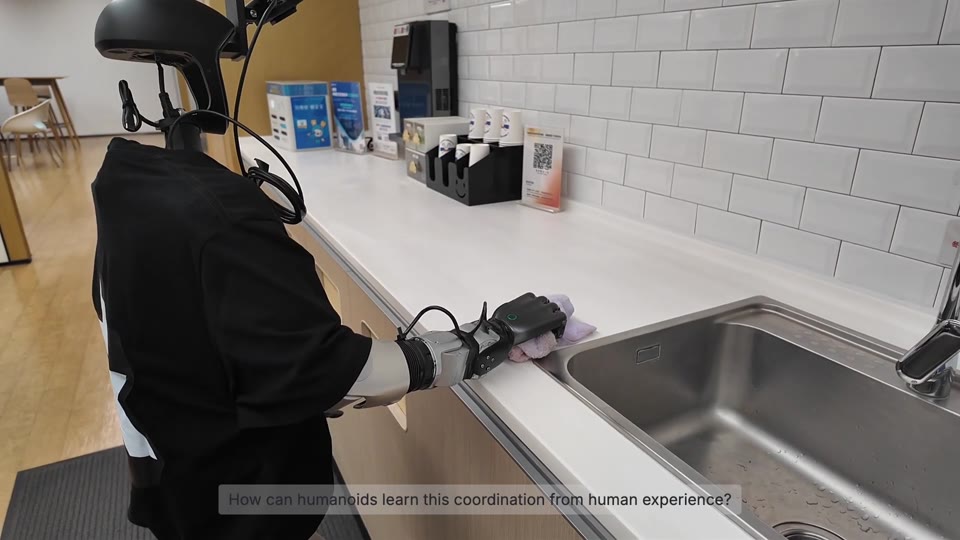
Towards a General Humanoid Loco-Manipulation Model via Egocentric Whole-Body Human Data Pretraining
Chongyang Xu, Zhao Wu, Jin Chen, Yiming Jiang, Jinhui Ye, Yuming Jiang, Shifeng Zhang, Ziliang Feng, Mu Xu, Yilun Chen, Li Lu, Steven C. H. Hoi
arXiv preprint, 2026
Introduces HumanVerse-500, a 500-hour egocentric whole-body dataset, and lambda-zero, a humanoid VLA policy that transfers human experience through three-stage training.
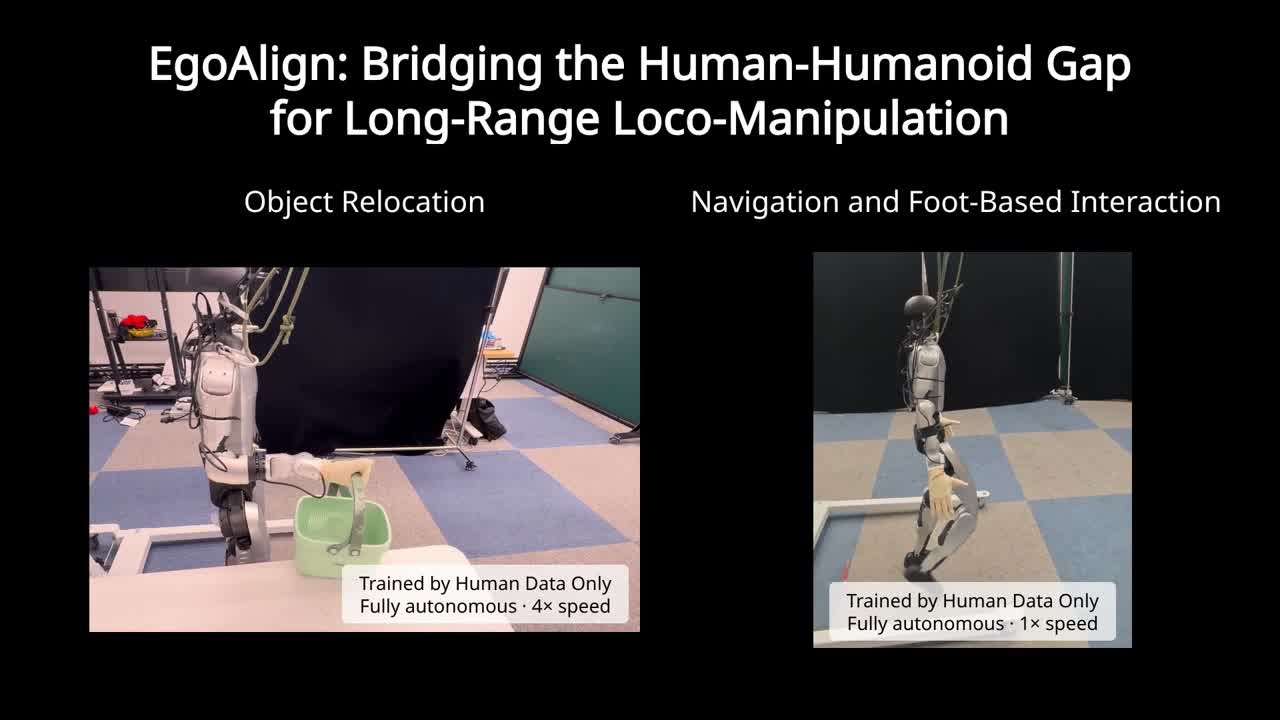
EgoAlign: Bridging the Human-Humanoid Gap for Long-Range Loco-Manipulation
Yiming Jiang, Jin Chen, Chongyang Xu, Yilun Chen, Aimin Hao, Yisheng He
arXiv preprint, 2026
Aligns human demonstrations with humanoid actions and states, enabling zero-shot long-range loco-manipulation without physical-robot task demonstrations.
EgoHumanoid: Unlocking In-the-Wild Loco-Manipulation with Robot-Free Egocentric Demonstration
Modi Shi*, Shijia Peng*, Jin Chen*, Haoran Jiang, Yinghui Li, Di Huang, Ping Luo, Hongyang Li, Li Chen
Robotics: Science and Systems (RSS), 2026
The first framework that trains on robot-free egocentric human videos and zero-shot deploys on bipedal humanoid robots.
χ₀: Resource-Aware Robust Manipulation via Taming Distributional Inconsistencies
Checheng Yu, Chonghao Sima, Gangcheng Jiang, Hai Zhang, Haoguang Mai, Hongyang Li, Huijie Wang, Jin Chen, Kaiyang Wu, Li Chen, Lirui Zhao, Modi Shi, Ping Luo, Qingwen Bu, Shijia Peng, Tianyu Li, Yibo Yuan (authors listed alphabetically)
RSS 2026 Workshop on Beyond Rigidity, 2026
A systematic study and optimization of dual-arm dexterous deformable-object manipulation; powered the first 24-hour non-stop laundry-folding livestream.
WholeBodyVLA: Towards Unified Latent VLA for Whole-Body Loco-Manipulation Control
Haoran Jiang*, Jin Chen*, Qingwen Bu, Li Chen, Modi Shi, Yanjie Zhang, Delong Li, Chuanzhe Suo, Chuang Wang, Zhihui Peng, Hongyang Li
International Conference on Learning Representations (ICLR), 2026
The first end-to-end VLA autonomy stack for bipedal humanoids, and the first to sustain over 1 minute of autonomous loco-manipulation on a bipedal humanoid.
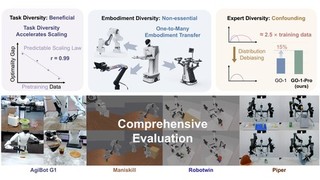
Is Diversity All You Need for Scalable Robotic Manipulation?
Modi Shi*, Li Chen*, Jin Chen*, Yuxiang Lu, Chiming Liu, Guanghui Ren, Ping Luo, Di Huang, Maoqing Yao, Hongyang Li
IEEE Transactions on Robotics (T-RO), 2026
A scaling-law study of how VLA foundation model performance scales with real-robot data diversity.
🎬 Demos
🎯 Academic Services
The 1st AgiBot World Challenge
IROS 2025 Competition, Tech Lead
Two tracks — Manipulation and World Model — attracting 300+ teams worldwide. Built on the AgiBot World platform with real-robot evaluation pipelines.
💻 Research Experience
- 2026.10 - Present, ABot-M, Alibaba, Research Intern.
- 2026.02 - 2026.09, Tongyi Lab, Alibaba (通义实验室), Research Intern.

- 2025.12 - 2026.01, KAI (超维动力), Research Intern.

- 2025.05 - 2025.11, AgiBot (智元机器人), Research Intern.
- 2024.10 - 2025.04, Shanghai AI Laboratory (上海人工智能实验室), Research Intern.
- 2023.09 - 2024.09, TeleAI (中国电信人工智能研究院), Research Intern.
📖 Educations
- 2025.09 - Present, Ph.D., Fudan University and Shanghai Innovation Institute.
- 2022.09 - 2025.06, M.S. in Mathematics, Xi’an Jiaotong University.
- 2018.09 - 2022.06, B.S. in Mathematics and Applied Mathematics, China University of Mining and Technology.
我是复旦大学与上海创智学院联合培养博士生,目前在 OpenDriveLab 从事研究工作,导师为李弘扬教授。
我的研究方向聚焦于人形机器人移动操作与人类数据规模化。欢迎通过邮件交流讨论。
🔥 最新动态
- 2026.09: 📢 EgoHumanoid-V2 发布于 arXiv!
- 2026.05: 🎉 EgoHumanoid 被 RSS 2026 接收并完整开源。
- 2026.02: 🎉 加入阿里巴巴通义实验室担任研究实习生。
- 2026.02: 📢 EgoHumanoid 发布于 arXiv:一个基于人类第一视角演示的人形机器人移动操作迁移框架。
- 2026.01: 🎉 WholeBodyVLA 被 ICLR 2026 接收。
📝 代表性论文
EgoHumanoid-V2: Human-to-Humanoid Transfer of Coordinated Whole-Body Skills for Loco-Manipulation
Jin Chen, Yiming Jiang, Chongyang Xu, Modi Shi, Shijia Peng, Li Chen, Tianyu Li, Mu Xu, Yilun Chen, Steven Hoi, Hongyang Li
arXiv preprint, 2026
通过由粗到细的动作对齐与视觉对齐,将第一视角人类示范中的全身协同技能迁移到人形机器人,并在四项真实任务上实现零样本部署。
Towards a General Humanoid Loco-Manipulation Model via Egocentric Whole-Body Human Data Pretraining
Chongyang Xu, Zhao Wu, Jin Chen, Yiming Jiang, Jinhui Ye, Yuming Jiang, Shifeng Zhang, Ziliang Feng, Mu Xu, Yilun Chen, Li Lu, Steven C. H. Hoi
arXiv preprint, 2026
提出 500 小时第一视角全身动作数据集 HumanVerse-500,通过三阶段训练将人类经验迁移到人形机器人全身移动操作策略 λ₀。
EgoAlign: Bridging the Human-Humanoid Gap for Long-Range Loco-Manipulation
Yiming Jiang, Jin Chen, Chongyang Xu, Yilun Chen, Aimin Hao, Yisheng He
arXiv preprint, 2026
将人类示范对齐为人形机器人可用的动作与状态监督,无需真实机器人任务示范,实现长距离移动操作的零样本部署。
EgoHumanoid: Unlocking In-the-Wild Loco-Manipulation with Robot-Free Egocentric Demonstration
Modi Shi*, Shijia Peng*, Jin Chen*, Haoran Jiang, Yinghui Li, Di Huang, Ping Luo, Hongyang Li, Li Chen
Robotics: Science and Systems (RSS), 2026
首个使用无机器人参与的第一视角人类视频训练,并可零样本部署到双足人形机器人上的框架。
χ₀: Resource-Aware Robust Manipulation via Taming Distributional Inconsistencies
Checheng Yu, Chonghao Sima, Gangcheng Jiang, Hai Zhang, Haoguang Mai, Hongyang Li, Huijie Wang, Jin Chen, Kaiyang Wu, Li Chen, Lirui Zhao, Modi Shi, Ping Luo, Qingwen Bu, Shijia Peng, Tianyu Li, Yibo Yuan 作者按字母序排列
RSS 2026 Workshop on Beyond Rigidity, 2026
面向双臂灵巧可变形物体操作的系统性研究与优化,支撑了首个 24 小时不间断叠衣直播。
WholeBodyVLA: Towards Unified Latent VLA for Whole-Body Loco-Manipulation Control
Haoran Jiang*, Jin Chen*, Qingwen Bu, Li Chen, Modi Shi, Yanjie Zhang, Delong Li, Chuanzhe Suo, Chuang Wang, Zhihui Peng, Hongyang Li
International Conference on Learning Representations (ICLR), 2026
首个面向双足人形机器人全身移动操作控制的端到端 VLA 自主系统,并首次实现超过 1 分钟的自主移动操作。
Is Diversity All You Need for Scalable Robotic Manipulation?
Modi Shi*, Li Chen*, Jin Chen*, Yuxiang Lu, Chiming Liu, Guanghui Ren, Ping Luo, Di Huang, Maoqing Yao, Hongyang Li
IEEE Transactions on Robotics (T-RO), 2026
研究真实机器人数据多样性如何影响 VLA 基础模型性能扩展规律。
🎬 演示
🎯 学术服务
IROS 2025 Competition, 技术负责人
赛事包含 Manipulation 与 World Model 两个赛道,吸引全球 300+ 支队伍参与。负责基于 AgiBot World 平台构建真实机器人评测流程。
💻 研究经历
- 2026.10 - 至今, 阿里巴巴 ABot-M, 研究实习生。
- 2026.02 - 2026.09, 阿里巴巴通义实验室, 研究实习生。
- 2025.12 - 2026.01, KAI(超维动力), 研究实习生。
- 2025.05 - 2025.11, AgiBot(智元机器人), 研究实习生。
- 2024.10 - 2025.04, 上海人工智能实验室, 研究实习生。
- 2023.09 - 2024.09, 中国电信人工智能研究院, 研究实习生。
📖 教育经历
- 2025.09 - 至今, 博士,复旦大学与上海创智学院。
- 2022.09 - 2025.06, 硕士,数学,西安交通大学。
- 2018.09 - 2022.06, 学士,数学与应用数学,中国矿业大学。